Continuing to publication
LeWAM · 2026-08-01
Goal: continue lewam to publication
Work Done:
- tested various flow policies, lerobot baselines, flow wams, tasks, etc.
- designed and printed wrist camera mount and pushT T
- tested and strengthened full data collection -> policy training -> rollout pipeline with full wandb integration
- found good CoRL 2026 workshop options
- great paper: https://arxiv.org/pdf/2512.01809
Successes:
- learning to start with VERY small scale experiments before increasing complexity
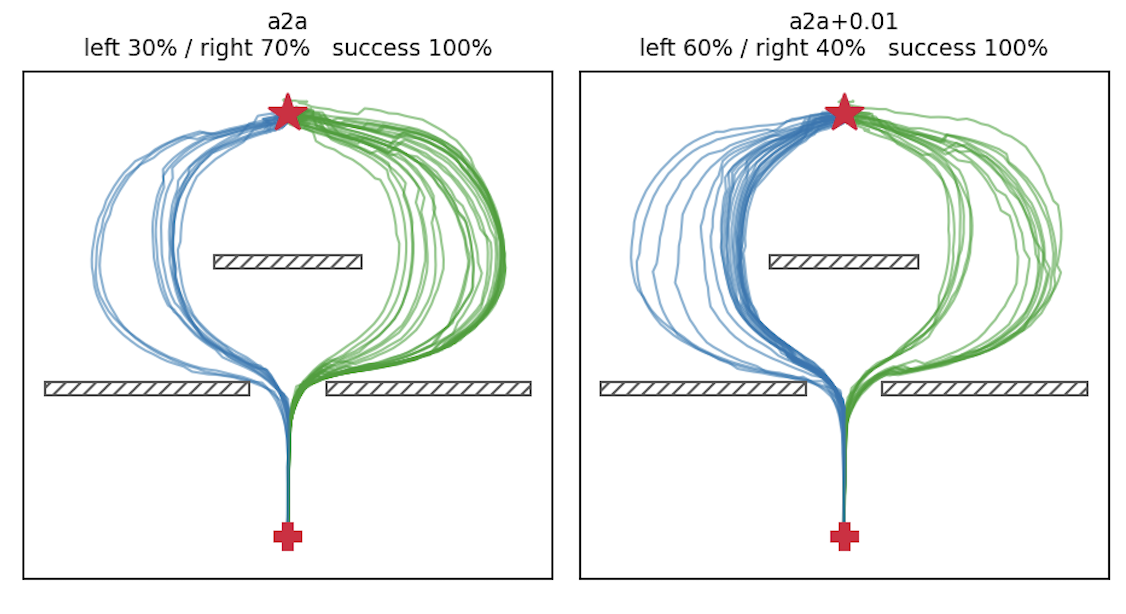
- e.g. found instability when using a2a flow matching in raw action space only once testing on a toy task
- 
- 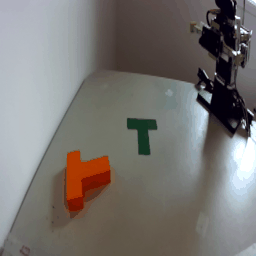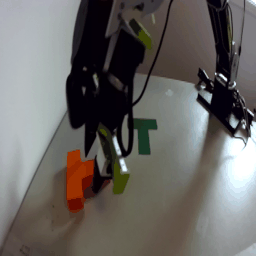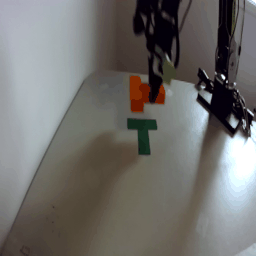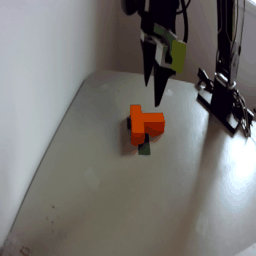
- (Above) Accidentally unnormalized, unexpectedly successful ACT baseline that lead to the discovery of a long standing normalization bug.
Failures:
- major normalization bug destroyed 2 weeks of testing and sent me on multiple tangents
- cable between wrist flex and wrist yaw motors on b601 broke
Next steps:
- Train all baselines on a few tasks
- incl. large WAMs
- train various latent, pixel space, and JEPA WAMs
- Write up results and hopefully get accepted to a CoRL 2026 workshop
Time spent: X hours