LeWAM
Latent-space World Action Model for multi-task manipulation. Honours thesis; unpublished until write-up.
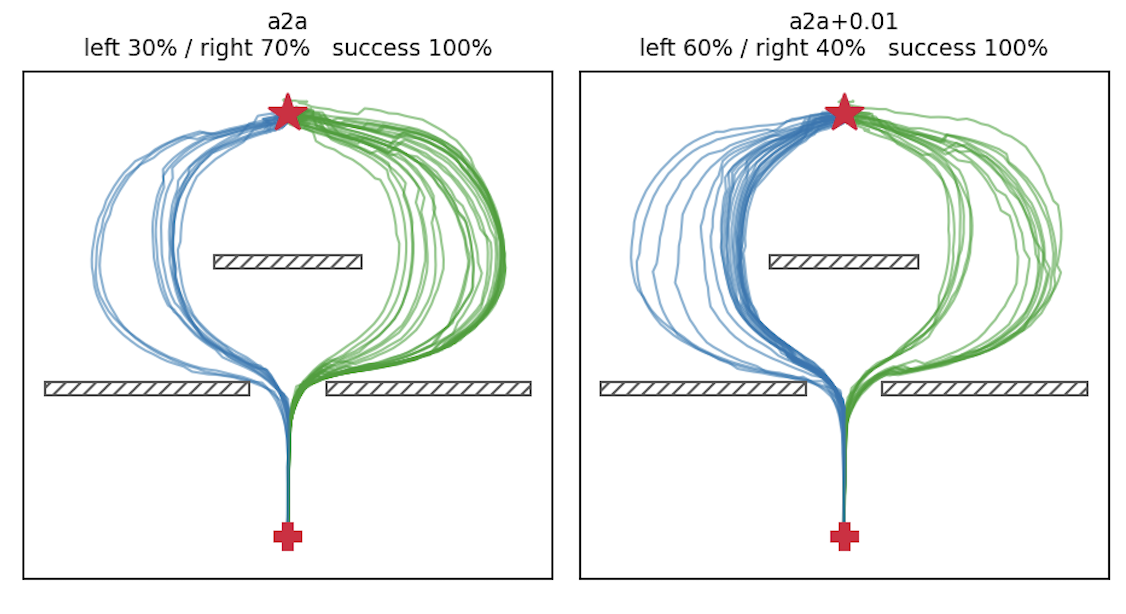 Continuing to publicationcontinue lewam to publication Work Done: tested various flow policies, lerobot baselines, flow wams, tasks, etc. designed and printed wrist camera mount and pushT T tested and stre…b601 arm and infracontinue lewam to publication at ICLR Work Done: built rebot b601 arm wrote and debugged lerobot data collection pipeline for b601 rewrote lewam repo to use new research template a…Starting honours thesisCreate honours thesis repo and start testing reBot arm in simulation Work Done: Created thesis repo using Boyuan Chen's research template repo read about the structure of the templ…Single-task training and testing LeWAM v0.3Train a single task pick and place policy using LeWAM Work Done: significantly improved dataloading speed by preprocessing before training av1 h264 encoding, long short gop length…
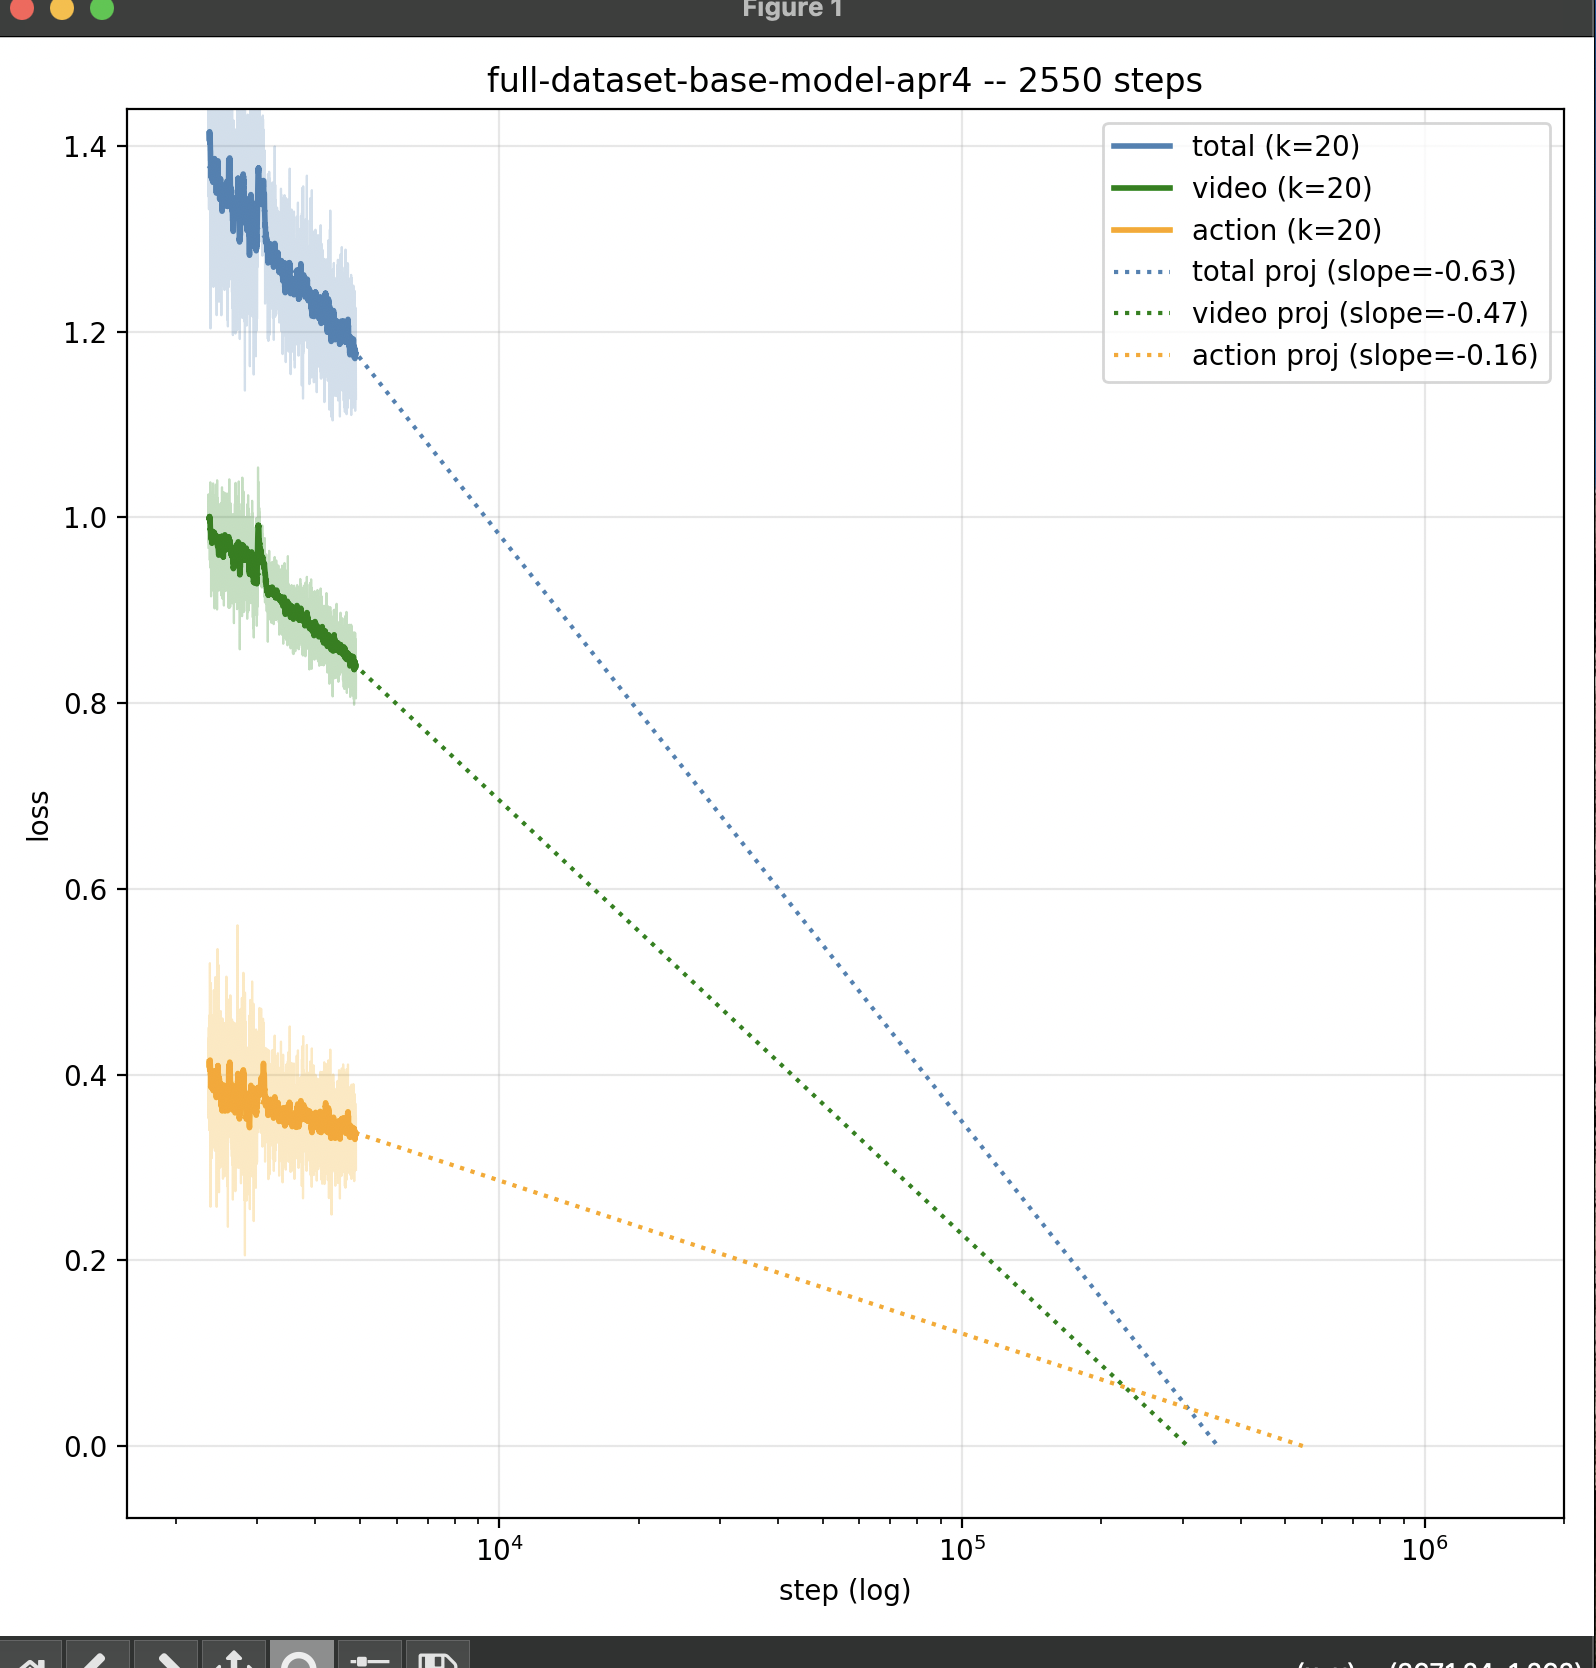 LeWAM scaling, arch updates, experimentsDevelop, test, and iterate LeWAM architecture and data pipeline Work Done: create v0.1 and 0.2 arch tested both architectures with pretraining, overfitting, policy rollouts, etc. s…
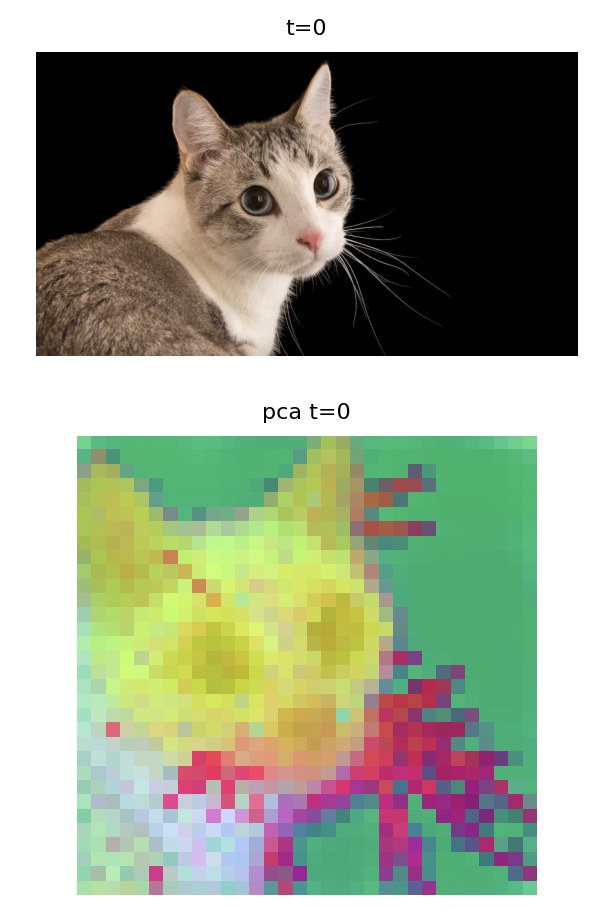 Planning LeWorldActionModelPlan and start working on a World Action Model experiment Work Done: Planned architecture, backbones, and datasets Read LeWorldModel, VJEPA2 Learned about flow matching and diffusi…