Finishing LeWAM for ICLR 2027
LeWAM · 2026-09-29
Goal: Finish all LeWAM experiments and submit to ICLR 2027
Work Done:
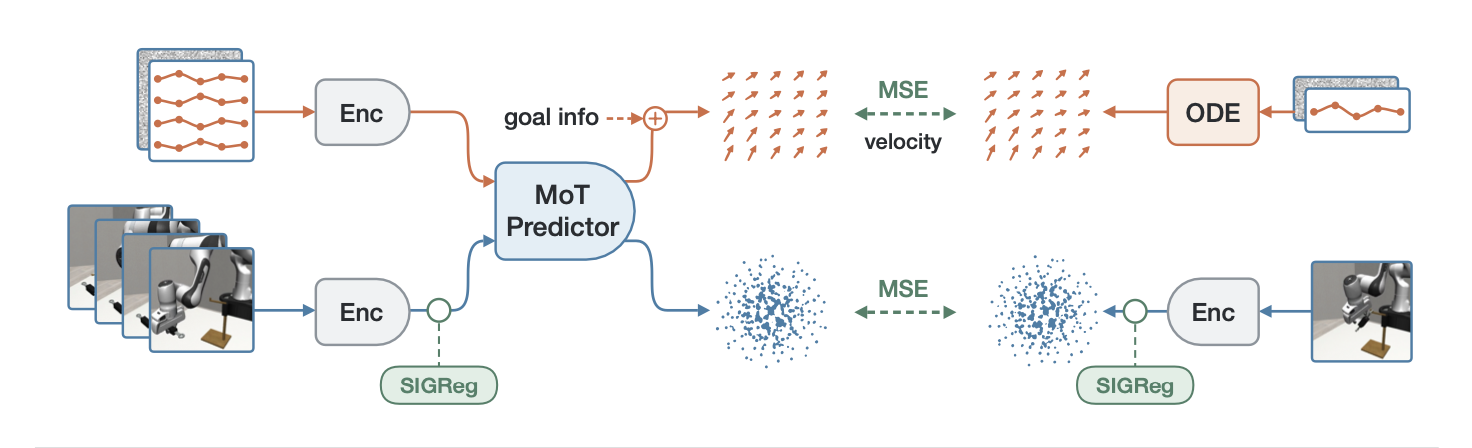
- Implemented final architecture used in both simulation and real robot experiments (MoT architecture with MSE prediction head and Flow action head)
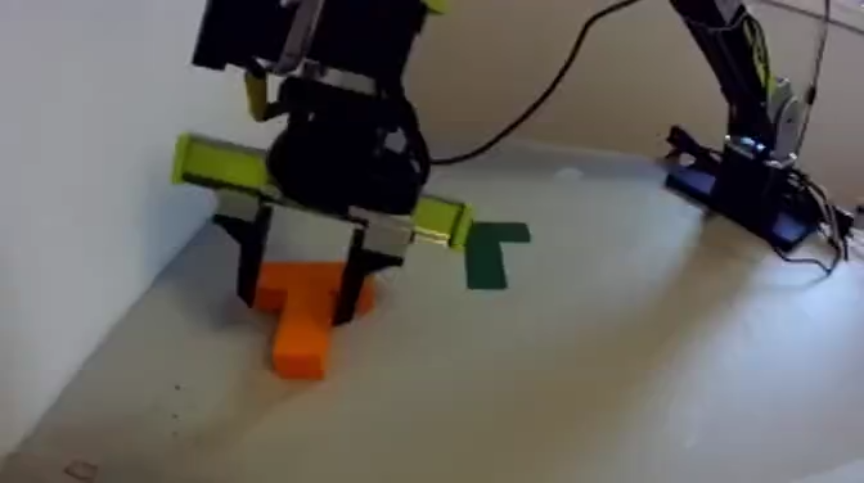
- Collected data for all tasks used in evaluation
- Ran all training runs, including DP and pi0.5 baselines
- Evaluated all models (30 evals * 4 models * 3 tasks TT)
Successes:
- LeWAM achieved competitive performance with Diffusion Policy and Pi0.5
- Submitted to ICLR 2027!
Failures:
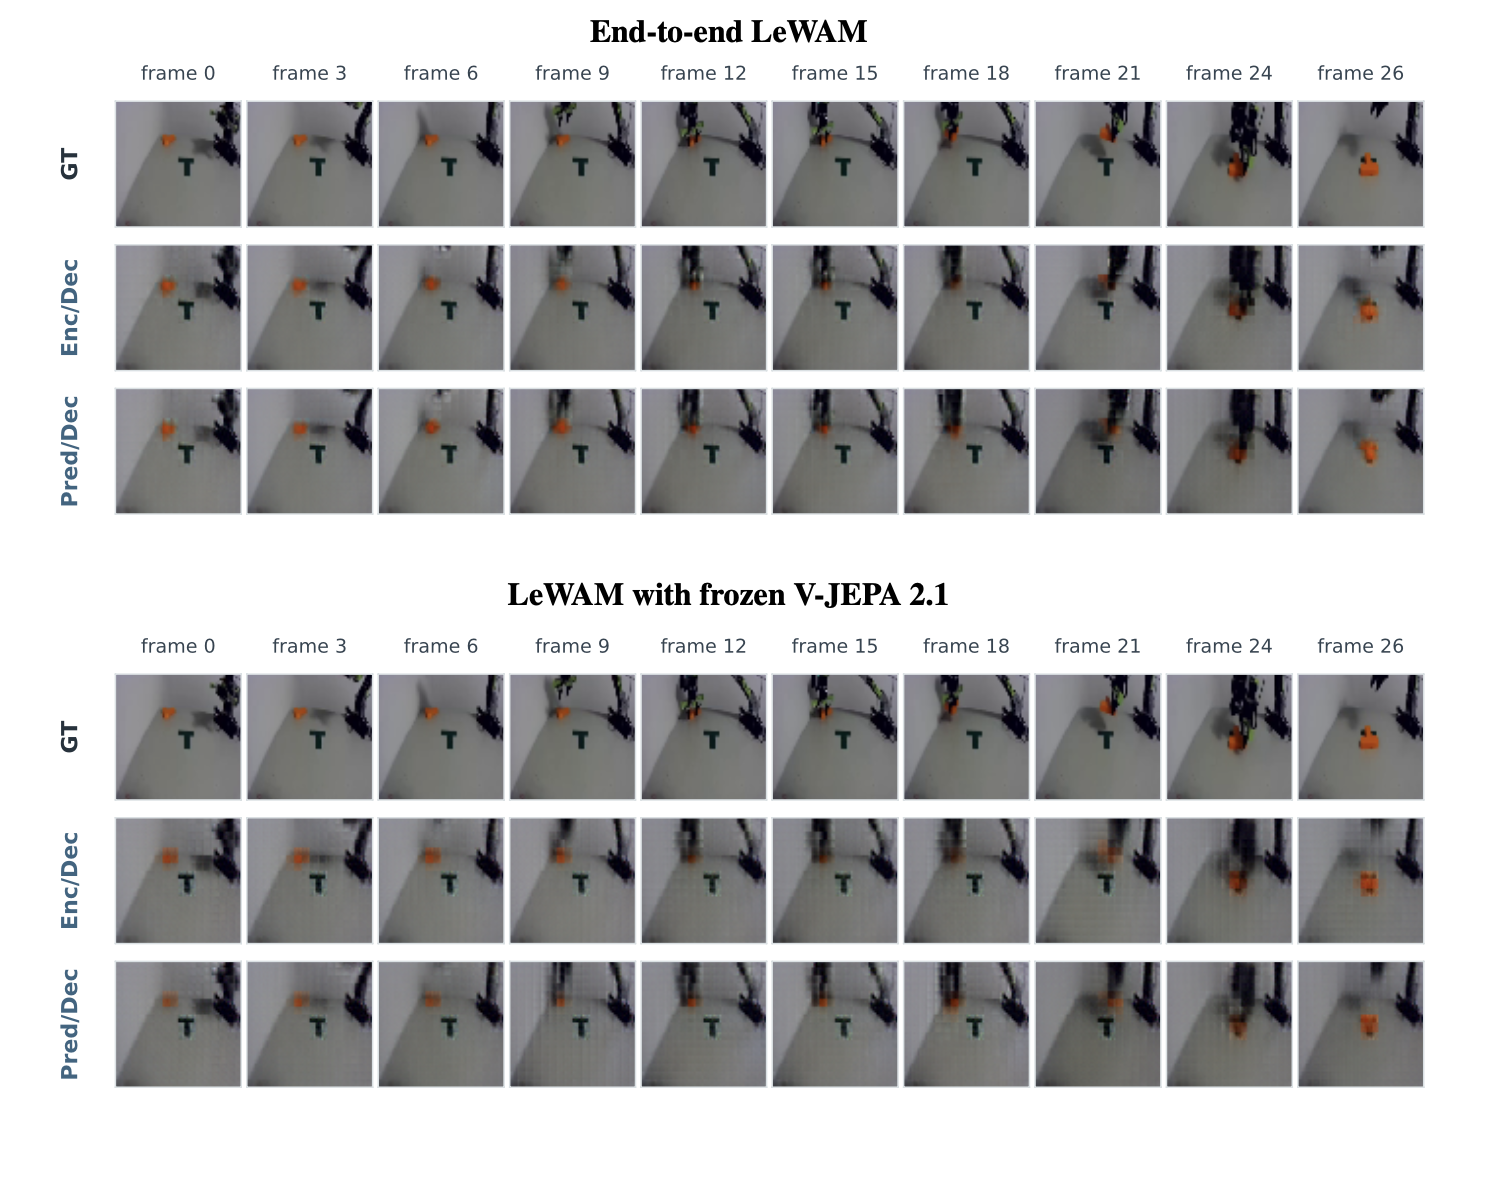
- Was not able to establish if future state / world modelling actually improves BC performance
- Did not run visual planning experiments in real life
- robot evals took SO LONG
Next steps:
- Wait for ICLR review
- Publish on arxiv
- Start working on honours thesis
- Port useful code from LeWAM into research template
Time spent: 100+ hours